
Version 0.2
One fisheye camera. Lanes, vehicles, lights and signs.
FCP is an open-source front-camera perception and ADAS stack. It uses only open models, public datasets and published methods, and it runs on real recordings today.
- Gap to CIPV
- 34.0 m
- Closing speed
- 0.0 m/s
- Time to collision
- not closing
- Collision warning
- Off
What the camera finds
FCP shows only what applies to your lane: the vehicle you follow, the light you must obey, the sign that is for you.
-
Lanes
Lane detection out to 60–80 m on the motorway. A second “far view” pass over the 120° fisheye image adds the long range.
60–80 m
-
Vehicles and CIPV
3D vehicle detection, selection of the closest in-path vehicle (CIPV) and time to collision (TTC). Filters remove oncoming traffic and false detections on guard rails.
CIPV, TTC
-
Traffic light of interest
Only the light that applies to your lane, with its state. The other lights at the junction stay out of the way.
Your lane only
-
Traffic signs of interest
Speed limits, no overtaking, priority road and more, shown only when they apply to you.
When it applies
Driving functions, open loop
Three functions run on top of the perception output. They compute what the car should do, but they do not actuate it.
- ACC
- Adaptive cruise control. Keeps a set speed and a safe gap to the CIPV.
- LKA
- Lane keeping assist. Steers back toward the lane centre from the detected lanes.
- FCW
- Forward collision warning. Warns when the time to collision with the CIPV gets too short.
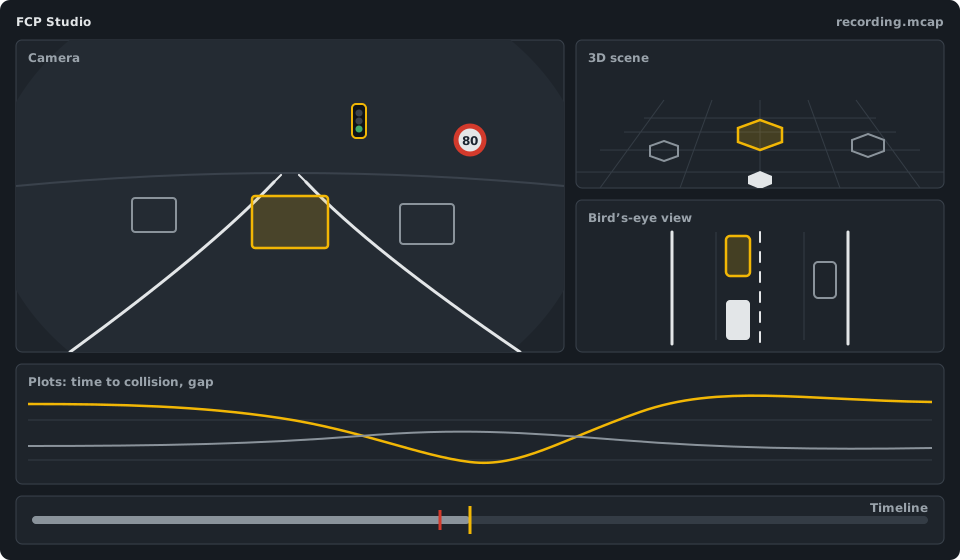
FCP Studio
A viewer for MCAP recordings, made for FCP. Camera view, 3D scene, bird’s-eye view, timeline and plots in one window, so you can see what the stack saw and why it decided.
Inside the stack
Fisheye camera
One 120° front camera. Calibration comes from the fisheye camera model.
Multi-task network
One network with a DINOv3 ViT-S backbone, trained on public datasets and running on TensorRT.
Tracking and distance
A camera-only pipeline with tracking and distance fusion.
Driving functions
ACC, LKA and FCW on top of the perception output, open loop.
Recording and review
Everything goes to MCAP and opens in FCP Studio.
How it is kept honest
- A modular architecture.
- A fault-injection suite that tests robustness.
- A benchmark suite.
- An issue tracker that links every issue to its fix.
Where it stands
Works today
Version 0.2 runs on my own recordings: motorway lanes, vehicles with CIPV and TTC, lights and signs of interest, and the three functions in open loop.
Needs work
Distance at long range, rare scenarios and night driving.
Next
Fine-tuning on real-world fisheye data. The source code is not public yet.
Build it with me
If you work on ADAS or computer vision, you can help with ideas, datasets, evaluation or code. Send me a message and tell me what interests you.
Contact on LinkedIn